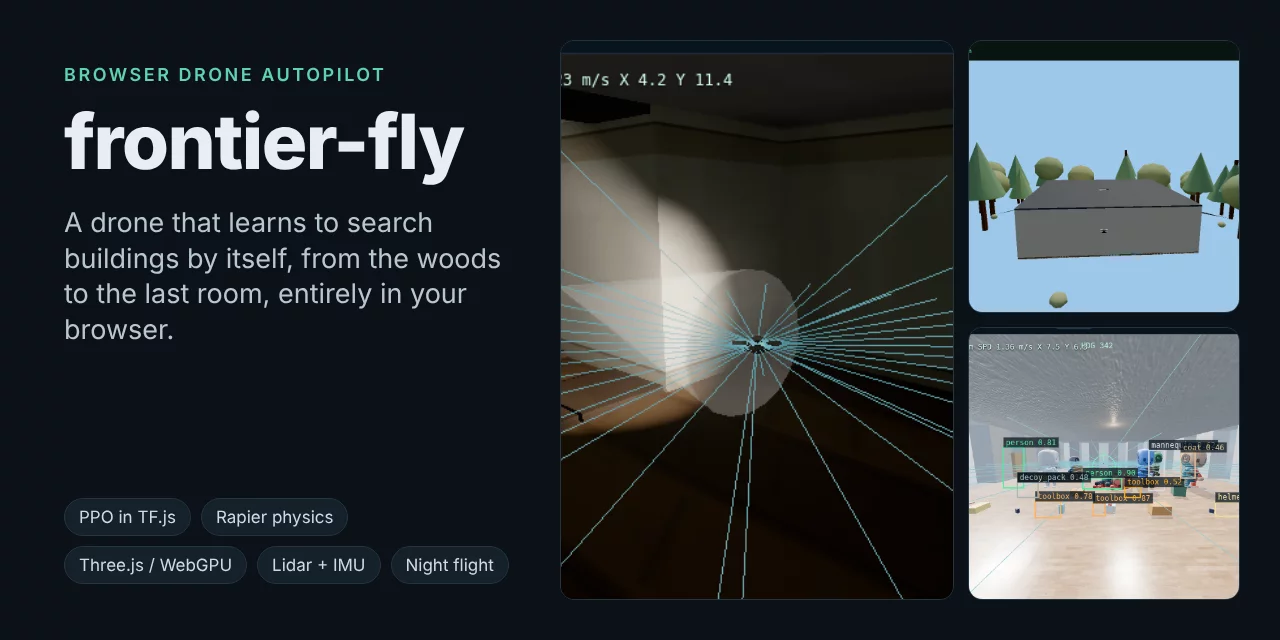

A search-and-rescue drone autopilot that searches buildings from the treeline to the last room, entirely in your browser. A small network, learned by imitation and fine-tuned with PPO, flies it on lidar alone, with a sensor-only planner as backup.
▶ Try it live · Mission film · How it works · Safety numbers · Tech report (PDF) · Project guide
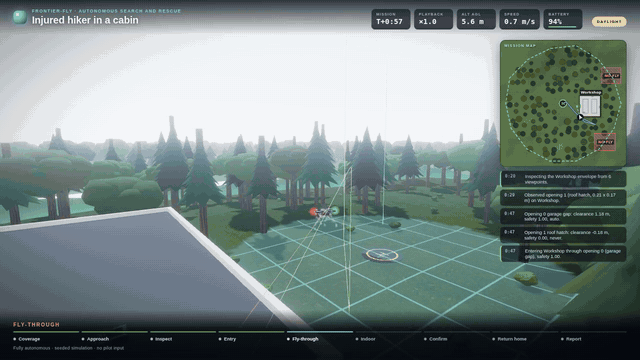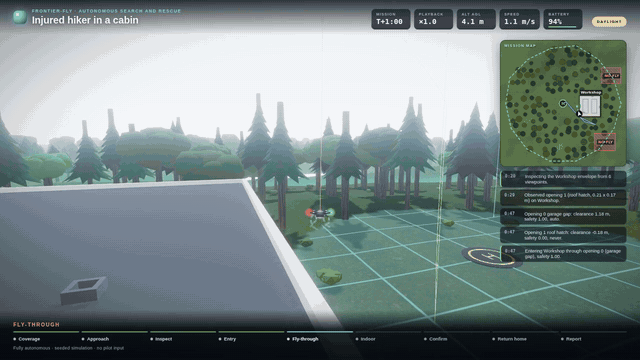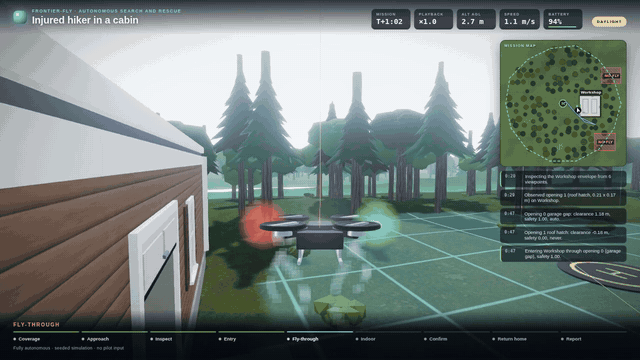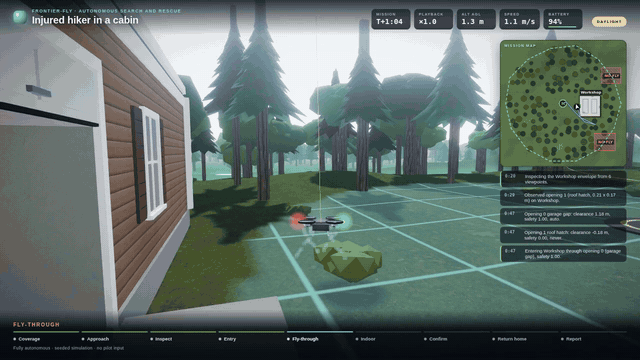
The drone sweeps a geofenced patch of woods, finds the building, picks an opening it fits through, searches room by room for a missing person or confirms the place is clear, flies home and files a report. Physics, sensors, training and rendering all run in the tab, with no server, and a seed rebuilds the same world exactly. Civilian and defensive use only: it searches, inspects and confirms clear, and never pursues anyone.
Results
| Question | Measured | On |
|---|---|---|
| How much of a new building does the trained policy search? | 80.0% (76.3–83.6%) at 3.4 wall contacts per flight; its teacher 67.3%, the sensor-only planner 65.5% with none | 30 fresh hard buildings |
| Does it work in the dark? | 80.0% at night with the lights off, 100.0% of day | the same buildings |
| Do whole missions end the right way? | 96.7% (91.7–98.7%) found the target or correctly cleared | 120 fixed-scenario missions on the quadrotor |
| How often does it call a building clear with someone inside? | 3.55% per flight (3.21–3.88%); 13.2% on sweeps of an occupied site | 2,000 importance-sampled flights, checked by 6,000 plain ones |
| How often does it hit something? | 2.70% per flight (1.99–3.41%) | 2,000 importance-sampled flights |
| Does it get home when something breaks? | 97.8% (96.7–98.6%) of faulted flights end safely | 960 flights with sensor, motor, battery, link, GNSS or wind faults |
Every number comes from seeds no model or setting was tuned on, with 95% intervals, and is regenerated from the study's JSON by npm run docs. The false-clear rate is the one to read first: it is why this is a research simulator and not a product. The project guide lists the other limits.
Run it
npm ci && npm run dev # Node 22, then open http://127.0.0.1:3000
The project guide covers the pages, every benchmark table, the studies, and how to train the policy. ARCHITECTURE.md maps the code, and CONTRIBUTING.md explains how to send changes. Code is MIT. Every asset is CC0, MIT, Apache-2.0 or CC BY 4.0 and listed in CREDITS.md.